Human-like motion
22 joints and 18 active degrees of freedom, including wrist pitch and lateral motion. The thumb has 4 active DOF and each other finger has 3, enabling coordinated, precise manipulation.
Anthropomorphic dexterous hand
Dexterity for embodied intelligence
Built for embodied intelligence and robotics, Gaoshan S1 combines an anthropomorphic five-finger design and lightweight tendon-driven architecture with multimodal sensing and high-performance motion control for precise grasping and complex manipulation.
For humanoid robots, robotics research, teleoperation and data collection.
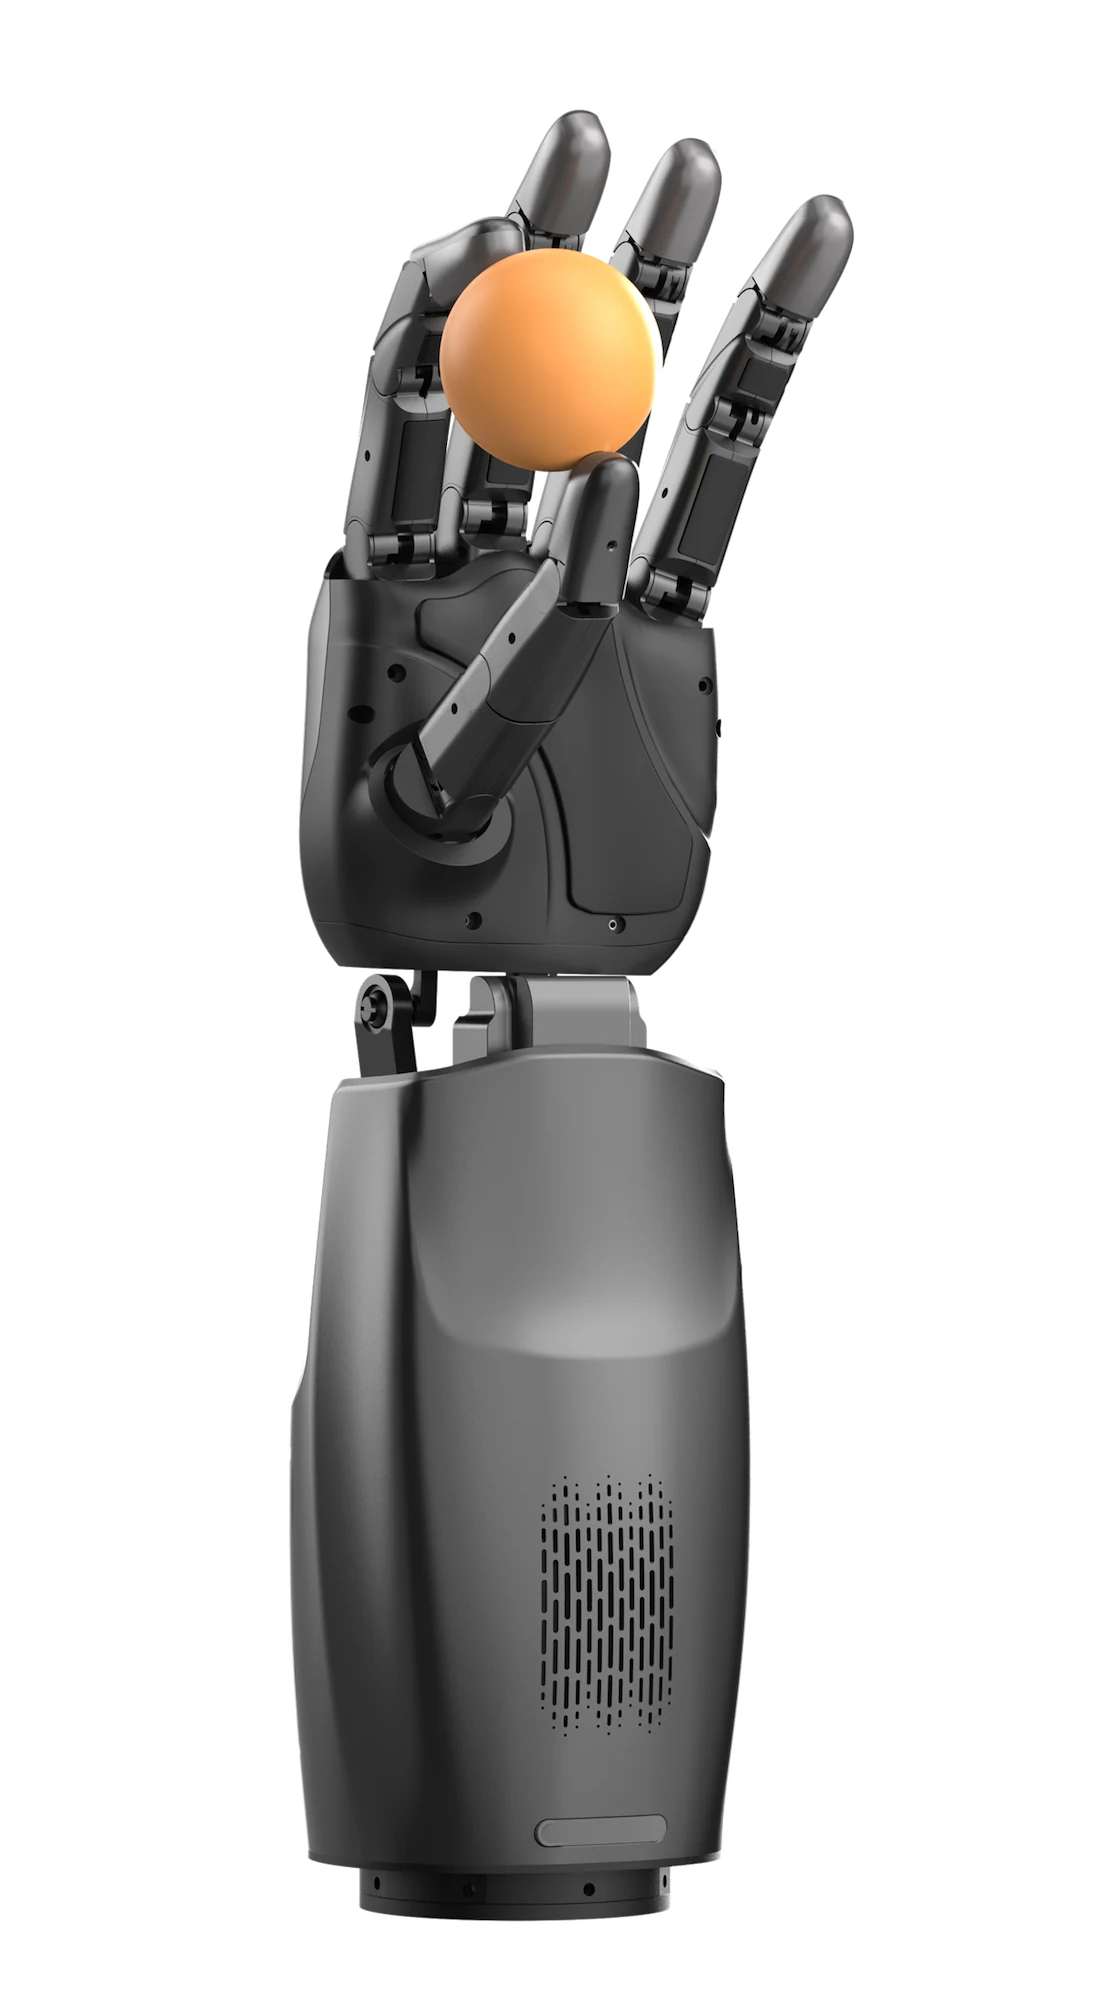
Drag to rotate · Scroll / pinch to zoom
Try a gesture
22 joints and 18 active degrees of freedom, including wrist pitch and lateral motion. The thumb has 4 active DOF and each other finger has 3, enabling coordinated, precise manipulation.
18-axis control with a control-loop frequency > 1 kHz, with torque, position, velocity, hybrid force-position and tactile-assisted hybrid control. A built-in motion library provides preset gestures and grasping actions.
3D fingertip tactile sensing with 116 sensing points per sensor, a minimum detectable force of 0.1 N and 1 mm spatial resolution. Joint angles, a 6-axis IMU, ambient temperature and humidity, and tendon-drive status complete the sensing system.
DEVELOPMENT & INTEGRATION
Values are interface control rates. EtherCAT is recommended and is currently the only interface supporting tactile array data transmission.
CONFIGURATIONS
S1-L-FT
S1-R-FT
S1-LR-FT
S1-L-FT + S1-R-FT
Included with each hand One dexterous hand, USB-to-RS-485 adapter, XT30 power cable, EtherCAT cable, CAN + RS-485 cable and protective carrying case.
Optional accessories 24 V / 7.5 A power adapter, display base and adapter flange.
Source: Gaoshan S1 Product Technical Specifications V0.1 (2026-09).